Research Project
This page presents selected research and engineering projects.
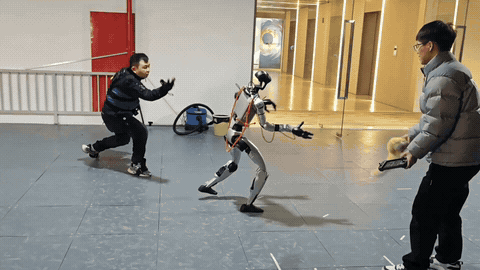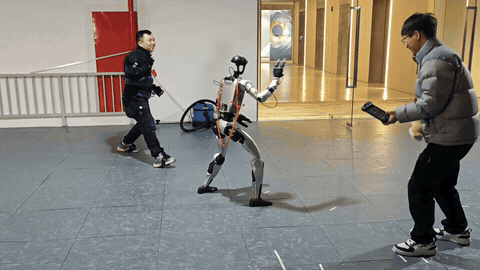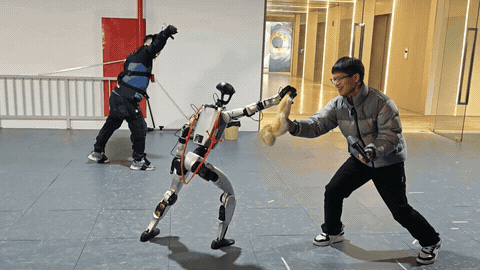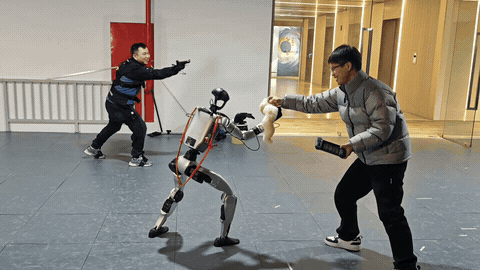
1. G1 Whole-Body Control
Whole-body control, motion tracking, and deployment experiments on the Unitree G1 humanoid robot.
2. O1 Uneven-Terrain Locomotion
Perception-aware locomotion and motion planning over uneven indoor and outdoor terrain on the Westlake Robot O1 platform.
3. K2 Whole-Body Control
Whole-body control and motion execution experiments on the Kepler K2 humanoid robot.
4. PM01 Whole-Body Control
Whole-body control and algorithm deployment experiments on the Booster Robotics PM01 humanoid robot.
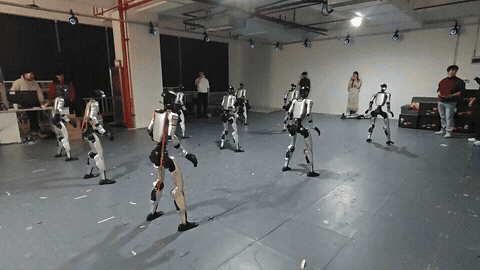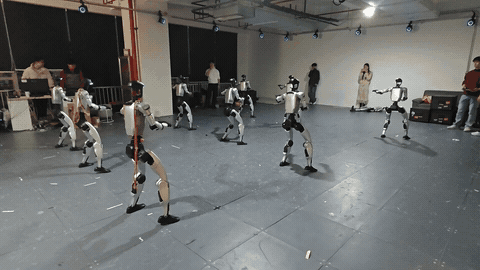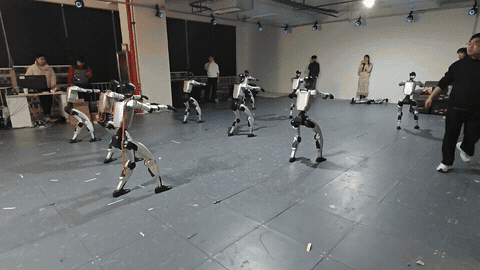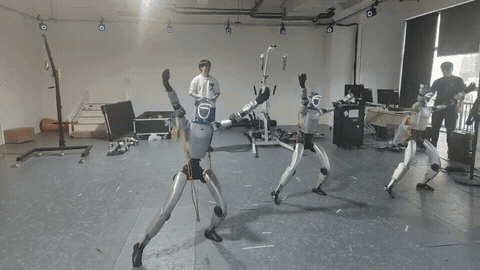
5. Multi-Robot Coordination
Selected demonstrations of multi-robot coordination and coordinated motion control.
6. Dataset Development
A dataset collection and preparation workflow for embodied-robot perception, learning, and control.
7. World-Model Simulation Experiments (WAM)
Simulation experiments on world-model-based robotic perception and control (WAM).
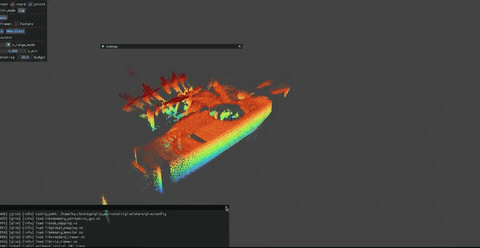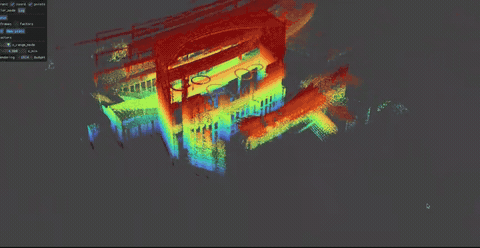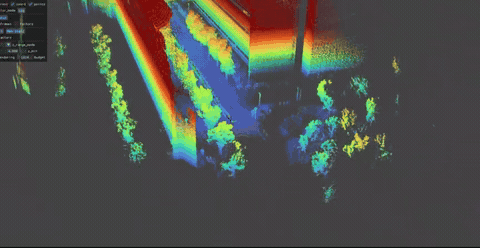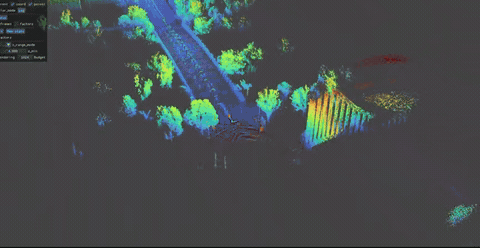
8. Large-Scale Outdoor High-Precision Mapping and Navigation
Large-scale outdoor high-precision mapping and navigation for mobile robots.